Mishel Johns
I'm interested in how humans and intelligent systems collaborate. I work at the intersection of Mechanical Engineering, Mechatronics, Software Engineering, Design and User Experience/Human Factors Research.
I'm interested in how humans and intelligent systems collaborate. I work at the intersection of Mechanical Engineering, Mechatronics, Software Engineering, Design and User Experience/Human Factors Research.
I work at Ford Motor Company on driver interaction technologies for SAE Level 2 and Level 3 automated vehicles. I'm also affiliated with the SAE Driving Automation Systems group and the Stanford Future Technologies Lab.
I completed my PhD in Mechanical Engineering with Profs. Wendy Ju and Larry Leifer at the Center for Design Research at Stanford. In my thesis, I explored collaboration between human drivers and automated driving systems.
I designed and evaluated systems that allow drivers and automated systems to share control of the vehicle, and to transition control between them. This process included:
Prototyping interfaces and automation behavior to improve human-agent cooperation performance and safety.
Mixing input from a driver and an automated driving system.
Timing and quality of takeover of control by a driver.
Driver Situational Awareness, Driving Performance, Cognitive Load, and Physiological Measurements.
A full list of my patents and publications is available on my Google Scholar profile.
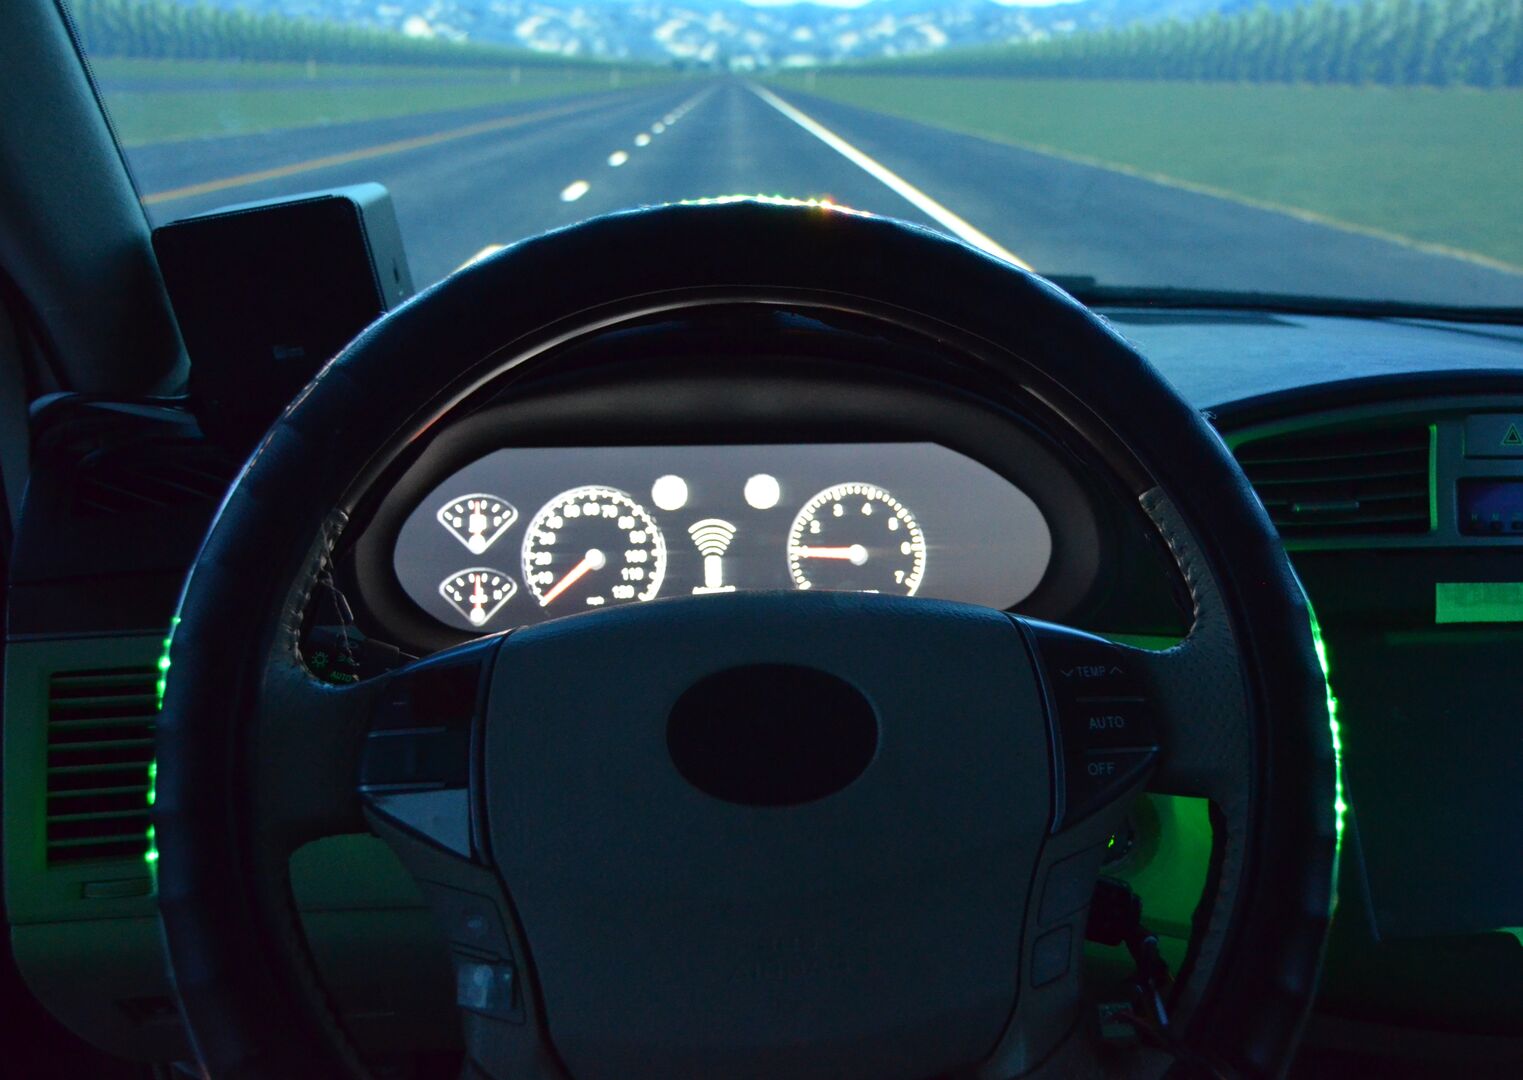
A Steering wheel cover with LEDs, linked to a driving simulator, providing realtime automation state info.
Read details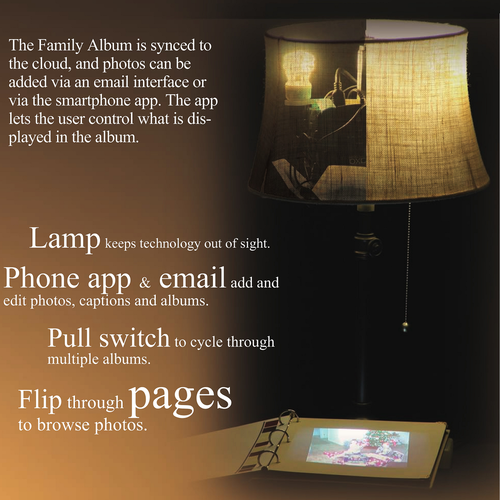
A communication device connecting digital-native children with non-digital-using older relatives in China.
Read details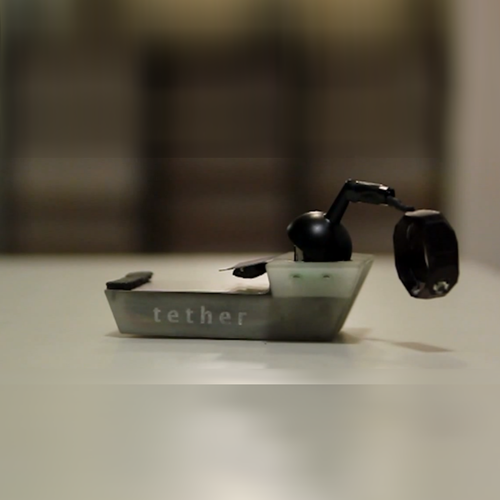
A smartphone clip-on device reading 3D positional input via Arduino, encoders, and retractable cord.
Read details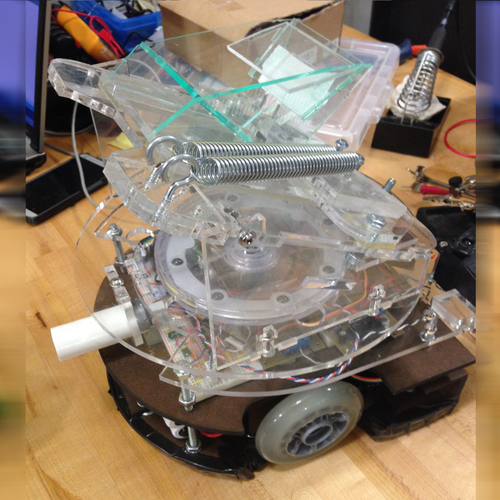
Winner of the 2014 Botcoin Tournament. Autonomous robot collecting poker chips and delivering them via IR sensing.
Read details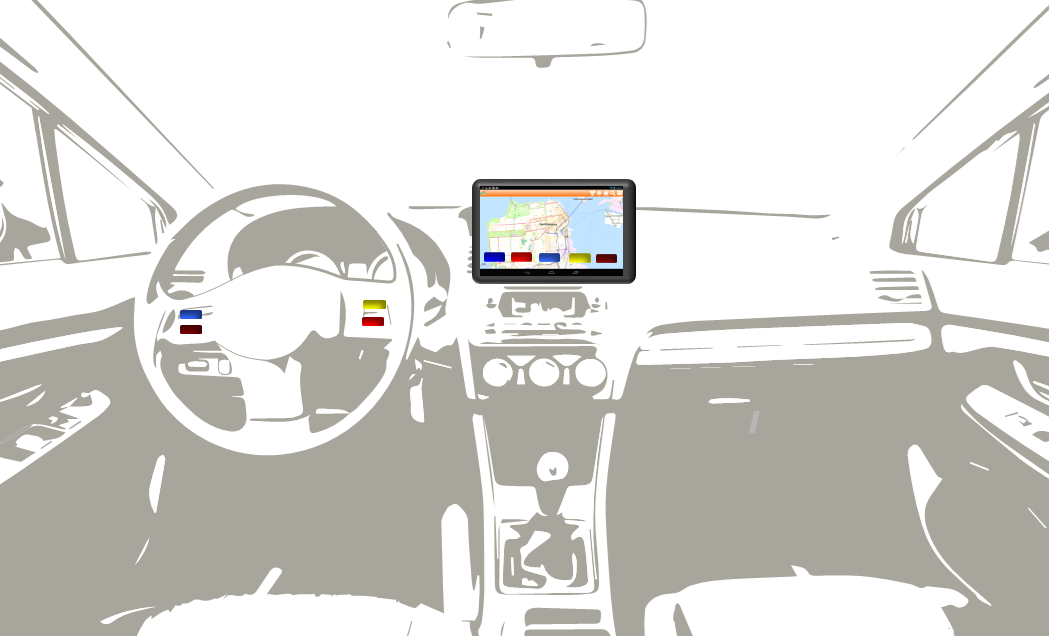
Interior design recommendations for data-capturing cars based on FMEA risk modeling and cost-worth analysis.
Read details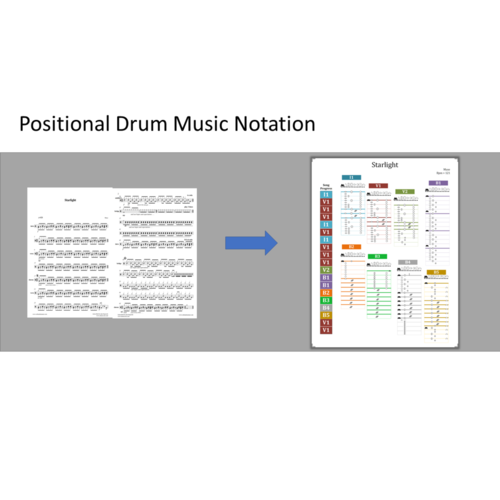
Alternative sheet music for drummers utilizing intuitive layouts and visual mappings built with D3.js.
Read detailsFeature and model selection for Automated Essay grading using Python and NLTK. More details here.
Ideation, quick prototyping, testing, and implementation of Advanced Driver Assistance System interfaces.
Driver interfaces and monitoring in autonomous vehicles utilizing ROS, C++, Eye Tracking, Arduino, and LEDs.
OpenSim controller stabilizing standing models via induced acceleration. More details here.
Ashok Leyland truck vibration simulation in MATLAB. Attenuated vibrations via LQR optimal controller design.
Simulating bipedal gait and walk-run transitions in MATLAB and Simulink at the Karlsruhe Institute for Technology.
Robotic gripper design utilizing an optical mouse to detect slip and dynamically adjust applied force.
Technical and Business case proposal on improving customer experience (second-placed team, 2012).
I enjoy backcountry camping and backpacking, road biking, running, social dancing, and making kinetic art. I sing tenor in the World Harmony Chorus in Palo Alto and dabble in ceramics and amateur radio.